app
KiCad - the KiCad Bridge
Public Made by Adomby adom
Reference implementation of the KiCad bridge: multi-instance Python server, forward path via kicad-cli, reverse path via in-process plugin. Most complex of the three bundled bridges.
← Commit history
Publish 1.0.127
5 files changed
+70−6
package.json+2−2@@ -1,6 +1,6 @@ { "slug": "kicad-bridge",- "version": "1.0.126",+ "version": "1.0.127", "type": "app", "description": "Skills for your container so your AI knows how to drive the KiCad bridge. The bridge runtime itself is the release zip; Adom Bridge loads that.", "tags": [@@ -115,4 +115,4 @@ "adom-desktop-kicad-bridge container approval is the first of two gates; the desktop gate is the second." ] }-}+}
page.json+31−4@@ -4,7 +4,7 @@ "slug": "kicad-bridge", "title": "KiCad - the KiCad Bridge", "brief": "Reference implementation of the KiCad bridge: multi-instance Python server, forward path via kicad-cli, reverse path via in-process plugin. Most complex of the three bundled bridges.",- "version": "1.0.111",+ "version": "1.0.127", "tags": [ "kicad", "pcb",@@ -53,7 +53,7 @@ "install_hint": "", "version_cmd": "" },- "readme": "# Adom Desktop \u2014 KiCad Bridge\n\nA **reverse bridge** that lets Adom Desktop (AD) \u2014 and the AI driving it \u2014 control the user's own\nKiCad on Windows: open and drive every editor, install symbol/footprint libraries, place parts, run\nDRC/ERC, export manufacturing files, and screenshot any window back to the AI.\n\nKiCad is the user's **host app**. The bridge *detects* an existing KiCad and, if none is present,\n*installs* one for them \u2014 it never asks the user to download or click through anything by hand.\n\n- **Page / docs:** https://wiki.adom.inc/adom/adom-desktop-kicad-bridge\n- **Bridge SDK:** https://wiki.adom.inc/adom/adom-desktop-bridges\n- **Verb namespace:** `kicad_*` \u00b7 **Status verb:** `kicad_bridge_status` \u00b7 **Health:** `GET /status`\n\n> Every screenshot in this README was captured on **ADOMBASELINE**, a stock Hyper-V VM with **no\n> GPU**, driven end-to-end through the bridge \u2014 install \u2192 libraries \u2192 editors \u2192 2D \u2192 3D. If it\n> renders there, it renders on a real laptop.\n\n---\n\n## Demo \u2014 narrated live editor tour (real screen recording)\n\n[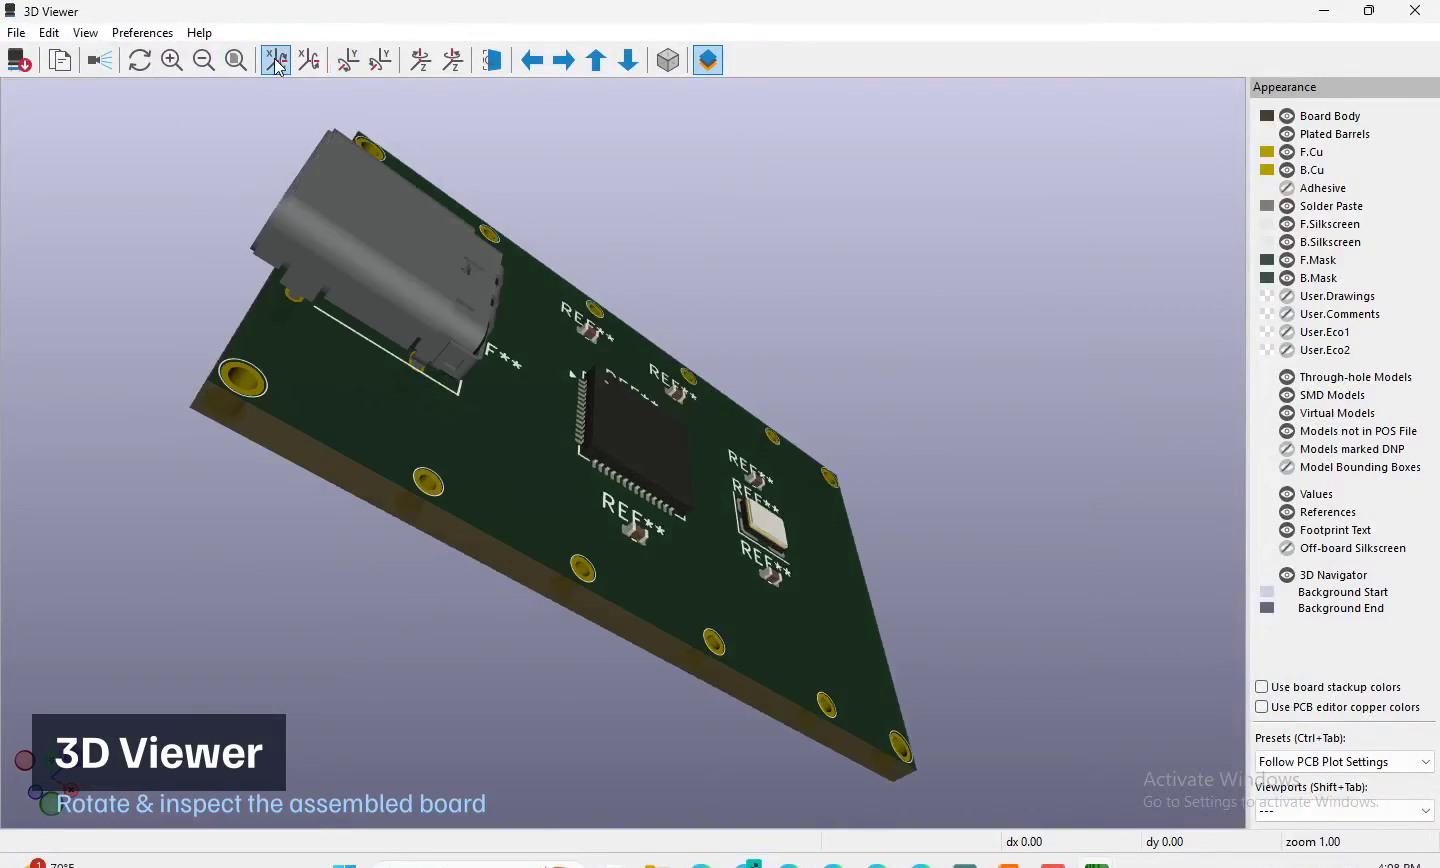](https://wiki.adom.inc/blob/app/adom-desktop-kicad-bridge/kicad-bridge-demo.mp4)\n\n**\u25b6 [Watch the demo](https://wiki.adom.inc/blob/app/adom-desktop-kicad-bridge/kicad-bridge-demo.mp4)** (48s, \ud83d\udd0a narrated) \u2014 the bridge driving real KiCad on a Windows VM: **select** a footprint and **zoom** the copper in the PCB editor, **rotate** the assembled board in 3D, then tour the schematic, symbol, and footprint editors. Genuine screen recording of the live windows (zoom / select / 3D rotation), narrated section by section \u2014 not animated stills.\n\n\n---\n\n## The demo verb \u2014 `kicad_demo`\n\nOne verb that shows the whole bridge off, built for the AI that demos Adom Desktop\nduring Hydrogen Desktop's install. Six beats, in the order a hardware person thinks:\n\n| Beat | Shows |\n|---|---|\n| 1 | the **schematic symbol** in the user's own Symbol Editor |\n| 2 | the **footprint** for that same part |\n| 3 | that part in **3D** |\n| 4 | a **schematic** using it (U1 + two 10k resistors) |\n| 5 | the **2D board layout** |\n| 6 | the finished **board in 3D** |\n\n```bash\nadom-desktop kicad_demo '{}' # start: prepares, warms KiCad, opens beat 1\nadom-desktop kicad_demo '{\"step\":\"footprint\"}' # ...then follow data.nextCall each time\nadom-desktop kicad_demo '{\"all\":true}' # bulk (non-interactive; slower than one request budget)\nadom-desktop kicad_close '{\"force\":true}' # tear down\n```\n\n**It narrates itself.** Every beat returns `say` (a line to speak), `pointOut`\n(what's actually on screen), `window` (match it in `kicad_screenshot_all`) and\n`nextCall`. One beat per call is the default precisely so the AI can talk, screenshot,\nthen move on.\n\n**It ships nothing.** The two demo parts, the schematic and the board are all\ngenerated in code, and the 3D bodies come from KiCad's *own* bundled\n`3dmodels/*.3dshapes` \u2014 so the runtime zip stays small and the 3D views are real.\nParts install into the user's real `Adom` library; the project lands in\n`Documents/adom-kicad-demo`.\n\n**No KiCad? It offers to install it.** `kicad_demo` returns an offer instead of an\nerror; `kicad_demo '{\"installKiCad\": true}'` silently installs the official build\n(per-user, no UAC) and then runs the tour. Watching the AI install your EDA tool is\nitself a good demo beat.\n\n**It never takes your screen.** Every window opens in the background and all input is\nwindow-targeted (UIA / `PostMessage`), so you can keep working while it runs.\n\n---\n\n## How it fits together\n\nThe bridge is a `spawn.kind: python` process AD launches on the user's machine (`entrypoint:\nserver.py`, `port: 0` \u2014 AD picks the port and passes `ADOM_BIND_HOST`). It speaks HTTP\n(`POST /command`, `GET /status`) and reaches KiCad through **four control surfaces**, picking the\nlightest one that can do the job.\n\n\n\n| # | Surface | Used for | Where |\n|---|---------|----------|-------|\n| 1 | **kicad-cli** (subprocess) | headless DRC/ERC, gerber/pdf/svg/step/bom export, format upgrade | `handlers/export.py`, `run_drc`, `run_erc`, `lint_*` |\n| 2 | **KiCad IPC (kipy)** | board/schematic introspection, confirmed footprint placement (KiCad 9+) | `handlers/place_footprint.py` |\n| 3 | **Embedded Python** | JSON-RPC *inside* each KiCad process, dispatched on its wx UI thread | `plugin_payload/adom_bridge.py`, `handlers/bridge_client.py` |\n| 4 | **Win32 / UIA / SendKeys** | open editors, screenshots, clicks/keys, dialog handling, window management | `handlers/kicad_ui.py`, `handlers/close_windows.py` |\n\n---\n\n## The window tour\n\nEverything below was opened and captured on the GPU-less VM. Sample data is the **RP2040 breakout**\ngenerated by `tour-pack-rp2040/` (an `AdomRP2040` symbol + `QFN-56_AdomRP2040` footprint + a board).\n\n### Schematic editor \u2014 `kicad_open_schematic`\n\nThe RP2040 breakout: the MCU (U1), USB-C, a 12 MHz crystal, decoupling, and mounting pins.\n\n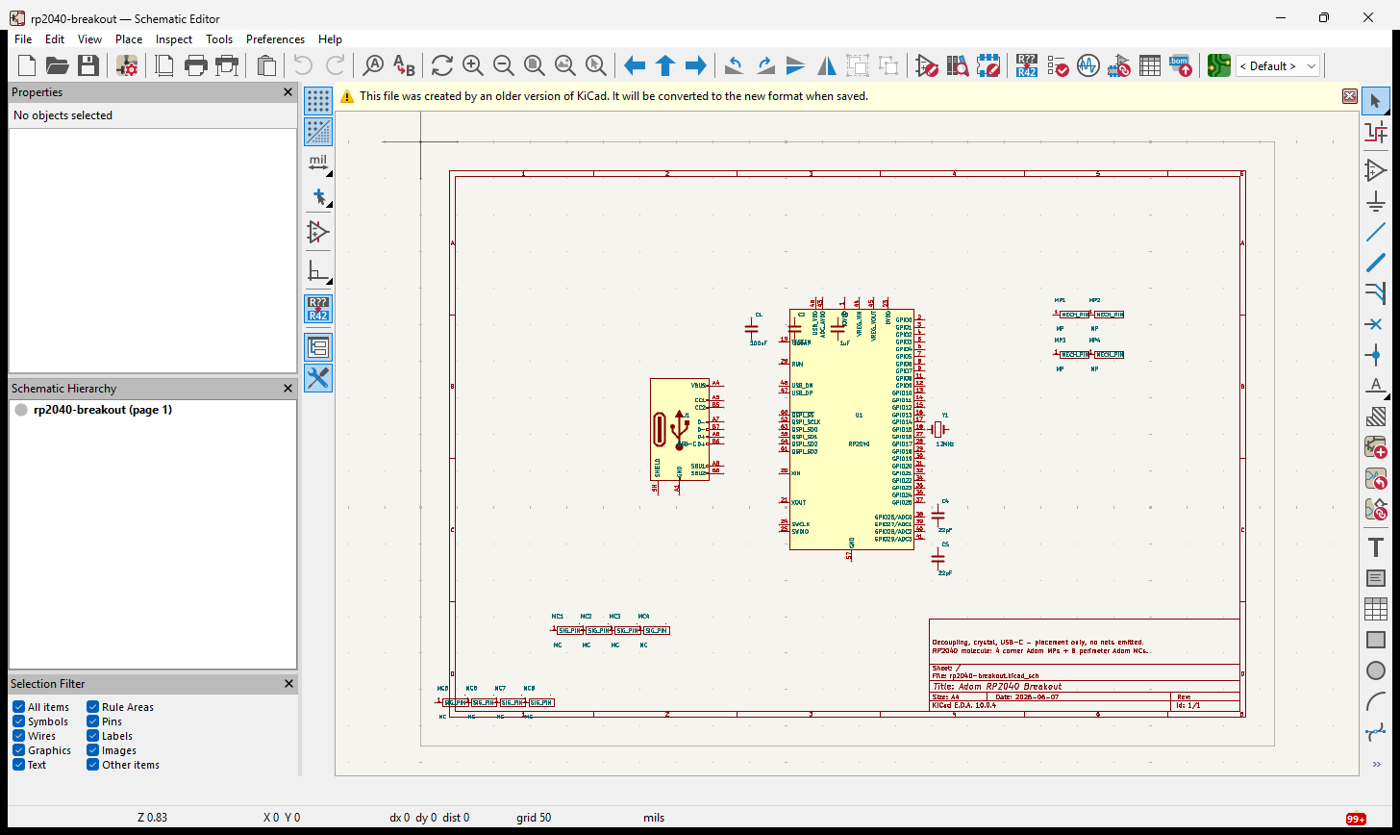\n\n### Symbol editor \u2014 `kicad_open_symbol_editor`\n\nOpens straight to a symbol (`kicad_install_symbol` puts it in a user library first).\n\n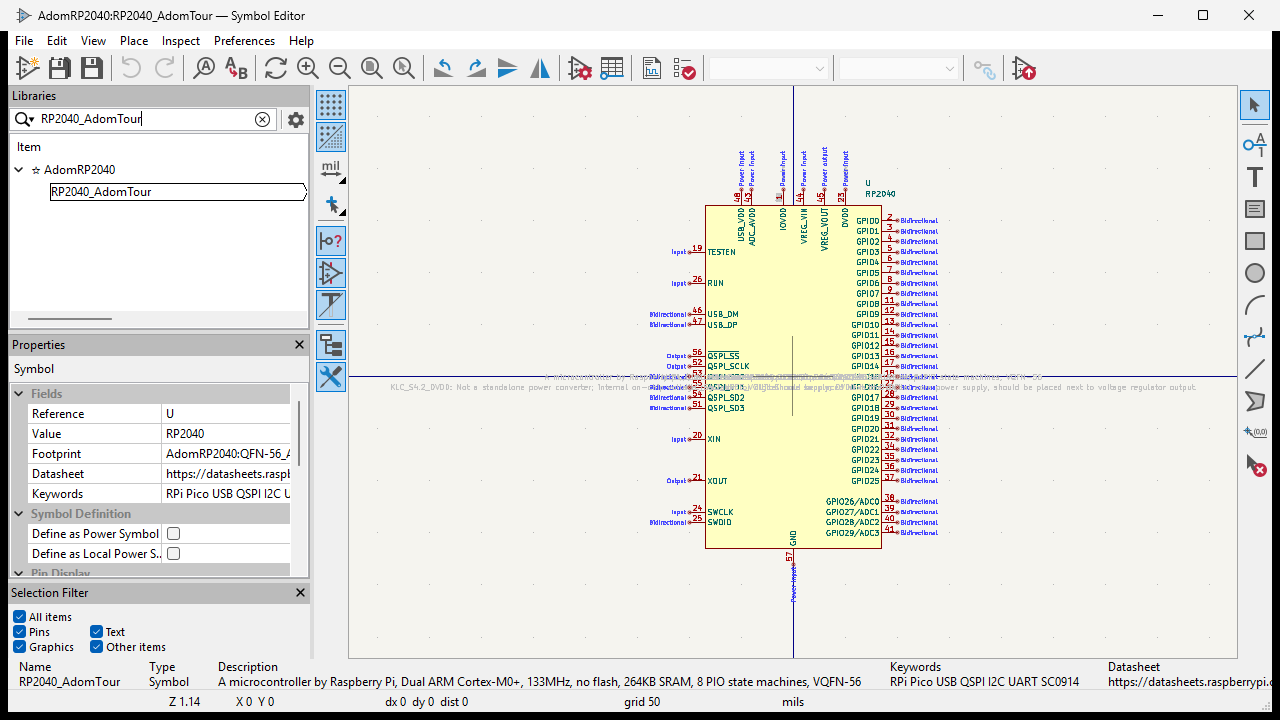\n\n### Footprint editor \u2014 `kicad_open_footprint_editor`\n\n`{\"footprintName\":\"QFN-56_AdomRP2040\",\"library\":\"AdomRP2040\"}` loads the part directly \u2014 56 pins +\nthermal pad, 7\u00d77 mm, 0.4 mm pitch, courtyard and silkscreen.\n\n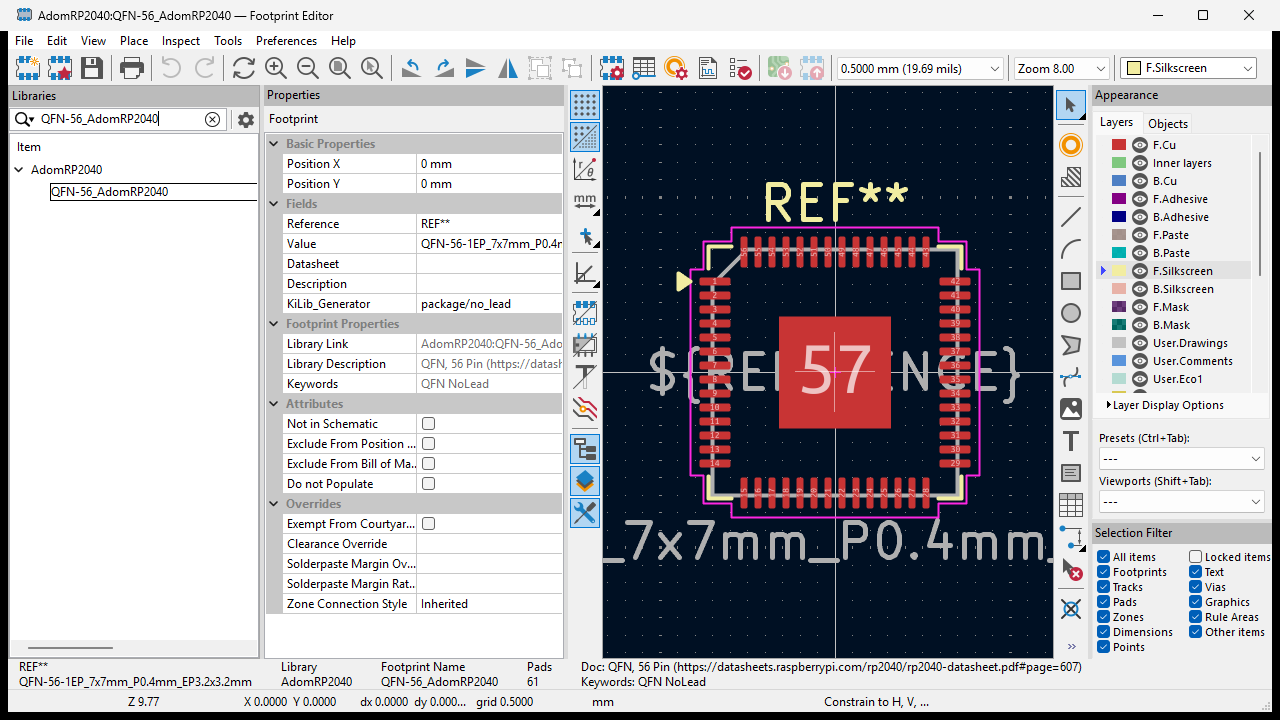\n\n### PCB editor (2D) \u2014 `kicad_open_board`\n\nThe routed breakout \u2014 copper, silkscreen, the QFN-56 land pattern, mounting holes.\n\n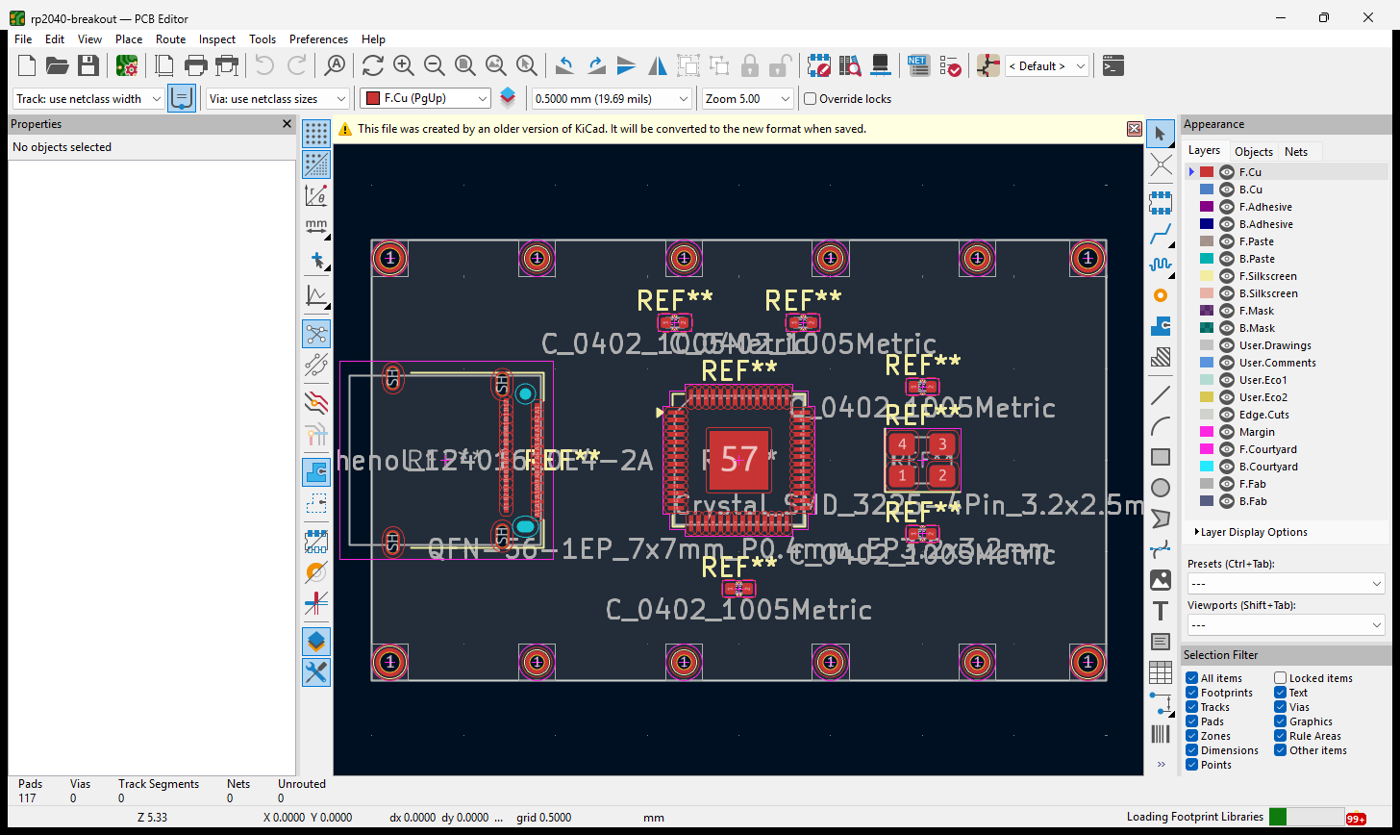\n\n### 3D viewer \u2014 `kicad_open_3d_viewer {\"editor\":\"pcb\"}`\n\nThe full board in 3D \u2014 board body, the USB-C connector's 3D model, the QFN chip body, SMD parts,\nplated through-holes. **Rendered on the CPU via the software-OpenGL fallback (below); reload 1.7 s.**\n\n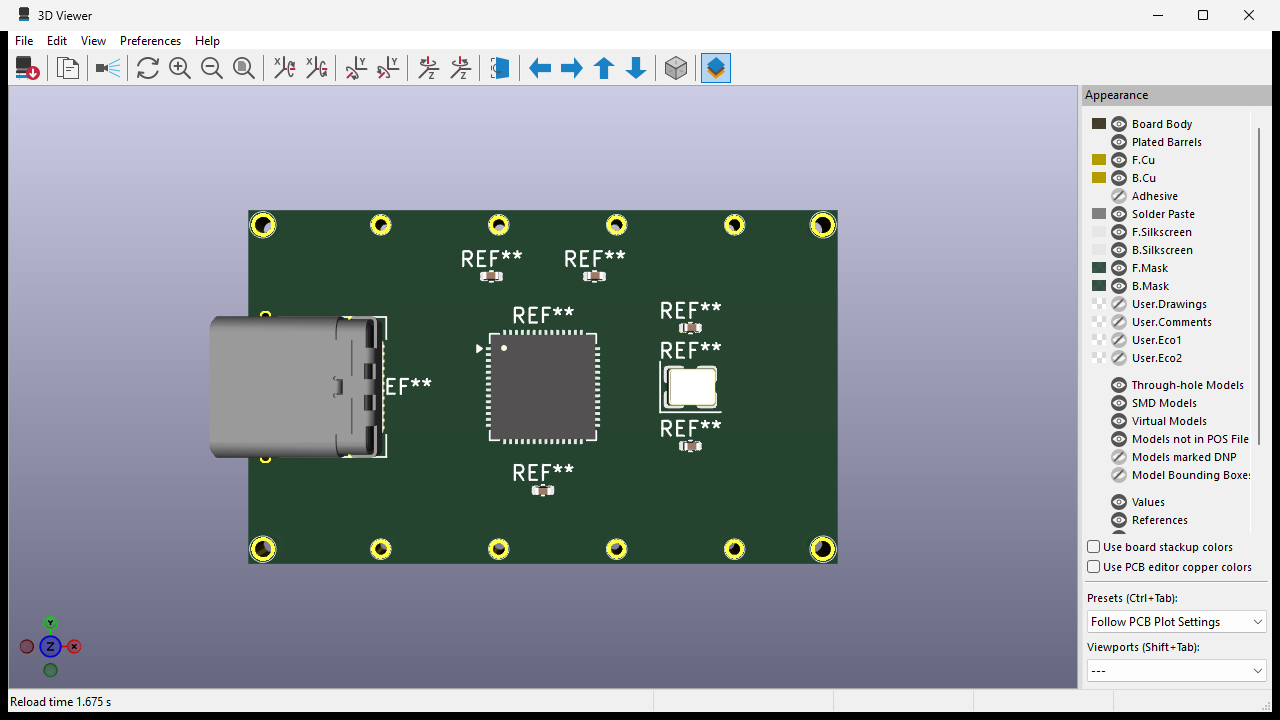\n\n---\n\n## Install & upgrade \u2014 zero manual steps\n\nThe bridge never tells the user to go download KiCad. `kicad_upgrade` fetches the official installer\nand runs it silently, picking the scope automatically:\n\n- **Elevated AD** \u2192 `/allusers /S` (system-wide, `%ProgramFiles%\\KiCad`).\n- **Non-elevated AD** \u2192 `/currentuser /S` (`%LocalAppData%\\Programs\\KiCad`, **no UAC prompt**).\n\n`kicad_readiness` reports whether KiCad is installed and ready without side effects; the AI routes on\nit before offering to install. Hard-won install details (all handled for you):\n\n- KiCad 10's NsisMultiUser installer **requires** a scope flag \u2014 bare `/S` errors `rc=666660`.\n- AD's portable Python has **no CA bundle**; the bridge ships `certs/cacert.pem` and uses it for TLS.\n- Downloads are size-checked against `Content-Length` (a truncated installer otherwise fails at NSIS).\n- `%APPDATA%/kicad/<ver>/` lib tables don't exist until first launch \u2014 the bridge **bootstraps** them\n so `install_library`/`install_footprint` work on a never-opened KiCad.\n- `kicad_upgrade {\"diagnoseOnly\":true}` reports token-elevation type + `EnableLUA` without installing.\n\n---\n\n## Dialogs & error handling \u2014 the bridge clears the pointless ones\n\nKiCad throws modal dialogs that stall automation. The bridge **scans every window owned by a running\nKiCad process** (by PID \u2014 reliable, unlike title matching), auto-expires the benign ones, screenshots\nwhat it dismissed, and returns a hint so the AI can decide what (if anything) to tell the user.\n\nAuto-expired benign dialogs include:\n\n- **\"Could not use OpenGL / falling back to software rendering\"** (GPU-less hosts).\n- **\"Welcome to KiCad \u2014 starting for the first time\"** first-run wizard (dismissing accepts defaults).\n- **\"This file was created by an older version of KiCad\"** conversion notice.\n\n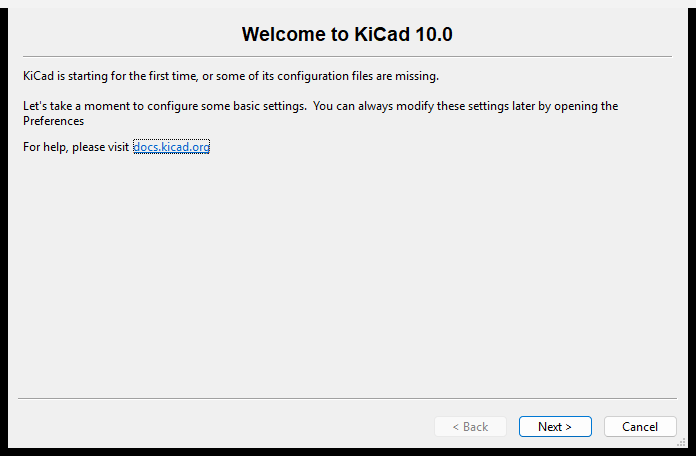\n\nVerbs:\n\n- `kicad_window_info` \u2014 lists windows and **self-heals** (auto-expires benign dialogs) by default.\n- `kicad_dismiss_dialogs {\"all\":true}` \u2014 clear everything blocking; `{\"screenshot\":true}` returns\n images of each; `{\"forceSoftwareCanvas\":true}` persists Cairo canvas; `{\"debug\":true}` dumps the\n raw PID-based scan.\n- `kicad_screenshot_all` \u2014 one call returns **every** open KiCad window, so the AI can spot an error\n dialog it didn't expect and read the message.\n\n---\n\n## Software-OpenGL fallback (last resort)\n\n`kicad_enable_software_opengl` deploys Mesa's `llvmpipe` (a CPU OpenGL rasterizer) into KiCad's `bin`\nso a box with **no usable GPU** \u2014 Hyper-V, RDP, headless CI \u2014 can still render the editors and the 3D\nviewer. This is how every 3D shot above exists.\n\n> \u26a0\ufe0f It renders on the CPU and is **slow**. It is a worst-case fallback only \u2014 a real GPU (or GPU-P /\n> DDA passthrough) is vastly better. The bridge keeps it so a GPU-less box isn't a dead end; it is\n> never suggested proactively.\n\n---\n\n## Verb reference\n\nAll 41 verbs (prefix `kicad_`). Call `kicad_describe` for the live catalog with per-verb hints,\nrelated verbs, and pitfalls.\n\n**Windows & UI** \u2014 `open_board`, `open_schematic`, `open_symbol_editor`, `open_footprint_editor`,\n`open_3d_viewer`, `open_editors`, `close_symbol_editor`, `close_footprint_editor`, `close_3d_viewer`,\n`close`, `window_info`, `dismiss_dialogs`, `screenshot_all`, `send_key`, `click`, `fix_keyboard`\n\n**Libraries & parts** \u2014 `install_library`, `install_symbol`, `install_footprint`, `install_plugin`,\n`place_footprint`, `adom_library_status`\n\n**Checks & export** \u2014 `run_drc`, `run_erc`, `lint_board`, `lint_schematic`, `lint_library`,\n`format_upgrade`, `export_gerber`, `export_pdf`, `export_svg`, `export_step`, `export_bom_csv`\n\n**Detect, install & meta** \u2014 `list_versions`, `readiness`, `describe`, `enable_software_opengl`,\n`check_for_updates`, `upgrade`, `bridge_status`, `bridge_call`\n\n---\n\n## Running / dependencies\n\nAD provisions everything; there is nothing to install by hand.\n\n- **Python** \u2265 3.11 (AD provisions it) \u2014 stdlib only, plus the bundled `certs/cacert.pem`.\n- **KiCad** \u2265 7.0 (host app; `kicad_upgrade` installs it if absent).\n- **OS:** Windows (macOS/Linux detection stubs exist; the GUI surfaces are Windows-first).\n\nThe bridge binds `ADOM_BIND_HOST` on an AD-assigned port \u2014 never `0.0.0.0`. Auto-updates via\n`updateManifestUrl` in `bridge.json`.\n\n---\n\n*Developer & publish notes live in `dev-skills/` and `publish-skills/` (source-only, never shipped to\na user install).*\n",+ "readme": "# Adom Desktop — KiCad Bridge\n\nA **reverse bridge** that lets Adom Desktop (AD) — and the AI driving it — control the user's own\nKiCad on Windows: open and drive every editor, install symbol/footprint libraries, place parts, run\nDRC/ERC, export manufacturing files, and screenshot any window back to the AI.\n\nKiCad is the user's **host app**. The bridge *detects* an existing KiCad and, if none is present,\n*installs* one for them — it never asks the user to download or click through anything by hand.\n\n- **Page / docs:** https://wiki.adom.inc/adom/adom-desktop-kicad-bridge\n- **Bridge SDK:** https://wiki.adom.inc/adom/adom-desktop-bridges\n- **Verb namespace:** `kicad_*` · **Status verb:** `kicad_bridge_status` · **Health:** `GET /status`\n\n> Every screenshot in this README was captured on **ADOMBASELINE**, a stock Hyper-V VM with **no\n> GPU**, driven end-to-end through the bridge — install → libraries → editors → 2D → 3D. If it\n> renders there, it renders on a real laptop.\n\n---\n\n## Demo — narrated live editor tour (real screen recording)\n\n[](https://wiki.adom.inc/blob/app/adom-desktop-kicad-bridge/kicad-bridge-demo.mp4)\n\n**▶ [Watch the demo](https://wiki.adom.inc/blob/app/adom-desktop-kicad-bridge/kicad-bridge-demo.mp4)** (48s, 🔊 narrated) — the bridge driving real KiCad on a Windows VM: **select** a footprint and **zoom** the copper in the PCB editor, **rotate** the assembled board in 3D, then tour the schematic, symbol, and footprint editors. Genuine screen recording of the live windows (zoom / select / 3D rotation), narrated section by section — not animated stills.\n\n\n---\n\n## The demo verb — `kicad_demo`\n\nOne verb that shows the whole bridge off, built for the AI that demos Adom Desktop\nduring Hydrogen Desktop's install. Six beats, in the order a hardware person thinks:\n\n| Beat | Shows |\n|---|---|\n| 1 | the **schematic symbol** in the user's own Symbol Editor |\n| 2 | the **footprint** for that same part |\n| 3 | that part in **3D** |\n| 4 | a **schematic** using it (U1 + two 10k resistors) |\n| 5 | the **2D board layout** |\n| 6 | the finished **board in 3D** |\n\n```bash\nadom-desktop kicad_demo '{}' # start: prepares, warms KiCad, opens beat 1\nadom-desktop kicad_demo '{\"step\":\"footprint\"}' # ...then follow data.nextCall each time\nadom-desktop kicad_demo '{\"all\":true}' # bulk (non-interactive; slower than one request budget)\nadom-desktop kicad_close '{\"force\":true}' # tear down\n```\n\n**It narrates itself.** Every beat returns `say` (a line to speak), `pointOut`\n(what's actually on screen), `window` (match it in `kicad_screenshot_all`) and\n`nextCall`. One beat per call is the default precisely so the AI can talk, screenshot,\nthen move on.\n\n**It ships nothing.** The two demo parts, the schematic and the board are all\ngenerated in code, and the 3D bodies come from KiCad's *own* bundled\n`3dmodels/*.3dshapes` — so the runtime zip stays small and the 3D views are real.\nParts install into the user's real `Adom` library; the project lands in\n`Documents/adom-kicad-demo`.\n\n**No KiCad? It offers to install it.** `kicad_demo` returns an offer instead of an\nerror; `kicad_demo '{\"installKiCad\": true}'` silently installs the official build\n(per-user, no UAC) and then runs the tour. Watching the AI install your EDA tool is\nitself a good demo beat.\n\n**It never takes your screen.** Every window opens in the background and all input is\nwindow-targeted (UIA / `PostMessage`), so you can keep working while it runs.\n\n---\n\n## How it fits together\n\nThe bridge is a `spawn.kind: python` process AD launches on the user's machine (`entrypoint:\nserver.py`, `port: 0` — AD picks the port and passes `ADOM_BIND_HOST`). It speaks HTTP\n(`POST /command`, `GET /status`) and reaches KiCad through **four control surfaces**, picking the\nlightest one that can do the job.\n\n\n\n| # | Surface | Used for | Where |\n|---|---------|----------|-------|\n| 1 | **kicad-cli** (subprocess) | headless DRC/ERC, gerber/pdf/svg/step/bom export, format upgrade | `handlers/export.py`, `run_drc`, `run_erc`, `lint_*` |\n| 2 | **KiCad IPC (kipy)** | board/schematic introspection, confirmed footprint placement (KiCad 9+) | `handlers/place_footprint.py` |\n| 3 | **Embedded Python** | JSON-RPC *inside* each KiCad process, dispatched on its wx UI thread | `plugin_payload/adom_bridge.py`, `handlers/bridge_client.py` |\n| 4 | **Win32 / UIA / SendKeys** | open editors, screenshots, clicks/keys, dialog handling, window management | `handlers/kicad_ui.py`, `handlers/close_windows.py` |\n\n---\n\n## The window tour\n\nEverything below was opened and captured on the GPU-less VM. Sample data is the **RP2040 breakout**\ngenerated by `tour-pack-rp2040/` (an `AdomRP2040` symbol + `QFN-56_AdomRP2040` footprint + a board).\n\n### Schematic editor — `kicad_open_schematic`\n\nThe RP2040 breakout: the MCU (U1), USB-C, a 12 MHz crystal, decoupling, and mounting pins.\n\n\n\n### Symbol editor — `kicad_open_symbol_editor`\n\nOpens straight to a symbol (`kicad_install_symbol` puts it in a user library first).\n\n\n\n### Footprint editor — `kicad_open_footprint_editor`\n\n`{\"footprintName\":\"QFN-56_AdomRP2040\",\"library\":\"AdomRP2040\"}` loads the part directly — 56 pins +\nthermal pad, 7×7 mm, 0.4 mm pitch, courtyard and silkscreen.\n\n\n\n### PCB editor (2D) — `kicad_open_board`\n\nThe routed breakout — copper, silkscreen, the QFN-56 land pattern, mounting holes.\n\n\n\n### 3D viewer — `kicad_open_3d_viewer {\"editor\":\"pcb\"}`\n\nThe full board in 3D — board body, the USB-C connector's 3D model, the QFN chip body, SMD parts,\nplated through-holes. **Rendered on the CPU via the software-OpenGL fallback (below); reload 1.7 s.**\n\n\n\n---\n\n## Install & upgrade — zero manual steps\n\nThe bridge never tells the user to go download KiCad. `kicad_upgrade` fetches the official installer\nand runs it silently, picking the scope automatically:\n\n- **Elevated AD** → `/allusers /S` (system-wide, `%ProgramFiles%\\KiCad`).\n- **Non-elevated AD** → `/currentuser /S` (`%LocalAppData%\\Programs\\KiCad`, **no UAC prompt**).\n\n`kicad_readiness` reports whether KiCad is installed and ready without side effects; the AI routes on\nit before offering to install. Hard-won install details (all handled for you):\n\n- KiCad 10's NsisMultiUser installer **requires** a scope flag — bare `/S` errors `rc=666660`.\n- AD's portable Python has **no CA bundle**; the bridge ships `certs/cacert.pem` and uses it for TLS.\n- Downloads are size-checked against `Content-Length` (a truncated installer otherwise fails at NSIS).\n- `%APPDATA%/kicad/<ver>/` lib tables don't exist until first launch — the bridge **bootstraps** them\n so `install_library`/`install_footprint` work on a never-opened KiCad.\n- `kicad_upgrade {\"diagnoseOnly\":true}` reports token-elevation type + `EnableLUA` without installing.\n\n---\n\n## Dialogs & error handling — the bridge clears the pointless ones\n\nKiCad throws modal dialogs that stall automation. The bridge **scans every window owned by a running\nKiCad process** (by PID — reliable, unlike title matching), auto-expires the benign ones, screenshots\nwhat it dismissed, and returns a hint so the AI can decide what (if anything) to tell the user.\n\nAuto-expired benign dialogs include:\n\n- **\"Could not use OpenGL / falling back to software rendering\"** (GPU-less hosts).\n- **\"Welcome to KiCad — starting for the first time\"** first-run wizard (dismissing accepts defaults).\n- **\"This file was created by an older version of KiCad\"** conversion notice.\n\n\n\nVerbs:\n\n- `kicad_window_info` — lists windows and **self-heals** (auto-expires benign dialogs) by default.\n- `kicad_dismiss_dialogs {\"all\":true}` — clear everything blocking; `{\"screenshot\":true}` returns\n images of each; `{\"forceSoftwareCanvas\":true}` persists Cairo canvas; `{\"debug\":true}` dumps the\n raw PID-based scan.\n- `kicad_screenshot_all` — one call returns **every** open KiCad window, so the AI can spot an error\n dialog it didn't expect and read the message.\n\n---\n\n## Software-OpenGL fallback (last resort)\n\n`kicad_enable_software_opengl` deploys Mesa's `llvmpipe` (a CPU OpenGL rasterizer) into KiCad's `bin`\nso a box with **no usable GPU** — Hyper-V, RDP, headless CI — can still render the editors and the 3D\nviewer. This is how every 3D shot above exists.\n\n> ⚠️ It renders on the CPU and is **slow**. It is a worst-case fallback only — a real GPU (or GPU-P /\n> DDA passthrough) is vastly better. The bridge keeps it so a GPU-less box isn't a dead end; it is\n> never suggested proactively.\n\n---\n\n## Verb reference\n\nAll 41 verbs (prefix `kicad_`). Call `kicad_describe` for the live catalog with per-verb hints,\nrelated verbs, and pitfalls.\n\n**Windows & UI** — `open_board`, `open_schematic`, `open_symbol_editor`, `open_footprint_editor`,\n`open_3d_viewer`, `open_editors`, `close_symbol_editor`, `close_footprint_editor`, `close_3d_viewer`,\n`close`, `window_info`, `dismiss_dialogs`, `screenshot_all`, `send_key`, `click`, `fix_keyboard`\n\n**Libraries & parts** — `install_library`, `install_symbol`, `install_footprint`, `install_plugin`,\n`place_footprint`, `adom_library_status`\n\n**Checks & export** — `run_drc`, `run_erc`, `lint_board`, `lint_schematic`, `lint_library`,\n`format_upgrade`, `export_gerber`, `export_pdf`, `export_svg`, `export_step`, `export_bom_csv`\n\n**Detect, install & meta** — `list_versions`, `readiness`, `describe`, `enable_software_opengl`,\n`check_for_updates`, `upgrade`, `bridge_status`, `bridge_call`\n\n---\n\n## Running / dependencies\n\nAD provisions everything; there is nothing to install by hand.\n\n- **Python** ≥ 3.11 (AD provisions it) — stdlib only, plus the bundled `certs/cacert.pem`.\n- **KiCad** ≥ 7.0 (host app; `kicad_upgrade` installs it if absent).\n- **OS:** Windows (macOS/Linux detection stubs exist; the GUI surfaces are Windows-first).\n\nThe bridge binds `ADOM_BIND_HOST` on an AD-assigned port — never `0.0.0.0`. Auto-updates via\n`updateManifestUrl` in `bridge.json`.\n\n---\n\n*Developer & publish notes live in `dev-skills/` and `publish-skills/` (source-only, never shipped to\na user install).*\n", "author": { "name": "John Lauer", "email": "[email protected]"@@ -90,6 +90,8 @@ "skills/kicad-tour/SKILL.md", "skills/kicad-tour/tour_runner.py", "skills/kicad-web-control/SKILL.md",+ "skills/kicad-uia/catalog.json",+ "skills/kicad-uia/SKILL.md", "skills/kicad-bridge-dev/SKILL.md", "skills/kicad-bridge-publish/SKILL.md", "skills/kicad-bridge-hero/SKILL.md",@@ -127,5 +129,30 @@ "binary_name": "adom-bridge-kicad", "authors": null, "author_handle": "john",- "authors_json": null-}+ "authors_json": null,+ "agent_permissions": {+ "allow_bash": [+ "adom-desktop-kicad-bridge"+ ],+ "allow": [+ "adom-desktop-kicad-bridge status, readiness, describe, diagnostics, window_info, state and open_editors are read-only queries against KiCad and the bridge; they change nothing.",+ "adom-desktop-kicad-bridge list_versions, list_footprints, list_symbols, list_design_rules and adom_library_status read library tables and files; they change nothing.",+ "adom-desktop-kicad-bridge plugin_diagnose, verb_times, progress, errors, log_tail, get_settings and check_for_updates read bridge logs and settings; they change nothing.",+ "adom-desktop-kicad-bridge screenshot_all captures KiCad windows to images; it changes nothing in KiCad.",+ "adom-desktop-kicad-bridge extract_netlist, trace_net, find_connections and analyze_connections read the open design; they change nothing.",+ "adom-desktop-kicad-bridge lint_board, lint_schematic, lint_library, run_drc and run_erc run KiCad's own checks and produce reports; they change nothing."+ ],+ "soft_deny": [+ "adom-desktop-kicad-bridge install_library, install_library_bundle, install_symbol, install_footprint, pcm_install and pcm_uninstall write to the user's KiCad libraries.",+ "adom-desktop-kicad-bridge adom_library_heal, set_design_rules, format_upgrade and set_settings rewrite library files, rules or settings.",+ "adom-desktop-kicad-bridge launch, close, close_symbol_editor, close_footprint_editor, close_3d_viewer and dismiss_dialogs start or stop KiCad windows.",+ "adom-desktop-kicad-bridge uninstall, install_plugin, upgrade and enable_software_opengl reconfigure the user's KiCad or the bridge.",+ "adom-desktop-kicad-bridge export_gerber, export_gerbers, export_pdf, export_svg, export_step, export_molecule, export_bom_csv and export_part write files.",+ "adom-desktop-kicad-bridge make_part_project and place_footprint edit or create designs; demo, send_key and click drive KiCad's windows and inject input."+ ],+ "environment": [+ "adom-desktop-kicad-bridge is the KiCad Bridge; every kicad verb also passes Adom Bridge's human-approval gate on the user's desktop (caller identity, per-call reason, Activity Log).",+ "adom-desktop-kicad-bridge container approval is the first of two gates; the desktop gate is the second."+ ]+ }+}
skills/kicad-bridge-dev/SKILL.md+14@@ -964,3 +964,17 @@ and the Symbol Editor listed the Adom library EMPTY. Three test symbols had bare - Captions need `reason` (ab refuses one without it: that is why two whole tours ran caption-less) and use `size: medium`. One line per beat, medium size, about the beat's length. - Bodies in 3D depend on KiCad's bundled 3D library being installed on the box (ConfRoomROG has none; AdomLapper does). Say so in the beat text instead of promising a body. - Never narrate over a running tour from the hands-free player, and never open the dashboard in the cloud workspace: the user watches in ah's dock webview and clicks Play there.+++## Live routing verbs (0.9.340)++`kicad_routing_state`, `kicad_route_net`, `kicad_remove_route`, `kicad_routing_validate` talk to+KiCad's IPC API (KiCad 10.0.1+). Before the first call on a box: `kicad_ipc_api {"enable":true}`+writes `api.enable_server` into kicad_common.json, then close and relaunch KiCad, because KiCad+reads the switch at start and rewrites the file on exit (enable AFTER closing when in doubt).+The acceptance run is `demo/routing/run_demo.py` against the fixture from+`demo/routing/make_fixture.py`, both modes (whole net, then `--per-trace` on a copper-free board),+plus the rejection checks (wrong net, stale revision, crossing route, dry run) and a native Ctrl+Z+/ Ctrl+Y on the PCB Editor window. Evidence goes to `demo/routing/evidence/<box>-<date>.json`.+Container tests: `PYTHONPATH=<linux pip target of requirements-routing.txt> python3 -m unittest discover -s tests`+(the vendored `routing_deps` are Windows wheels; the container needs its own target).
skills/kicad-bridge-publish/SKILL.md+19@@ -200,3 +200,22 @@ from then on it follows the tier by itself. **Never create a release on adom/insiders** - it shares a version namespace with that page's skills package (adom/wiki#170). The zip stays here.+++## Vendored dependencies and the tested-bytes rule (0.9.340, 2026-09-07)++- The live routing verbs need kicad-python (protobuf, pynng, cffi). Those are NOT pip-installed on+ the desktop: `tools/vendor_routing_deps.py` downloads Windows x64 wheels for CPython 3.11, 3.12+ and 3.13 into `routing_deps/cp3xx/` and `tools/release_files.json` lists that directory under+ `"dirs"`. `handlers/live_routing.py` appends the tree matching the running interpreter. The tree+ ships in the zip but is never pushed to the page repo (rebuild it, do not commit it).+- Test the exact bytes you ship: build once without `--publish`, stage that zip on the test box+ (dev-pin the cache, `bridge_kill` with confirm, back the cache up, `Expand-Archive` the zip over+ it, `bridge_resume`), run the acceptance, then publish with `--reuse-zip` so the sha256 in the+ evidence is the sha256 in the manifest. A rebuild changes zip timestamps and therefore the hash.+- A dashboard poll can respawn the old bridge process between `bridge_kill` and your unpack.+ Read `kicad_status.bridgeVersion` after `bridge_resume`; if it is still the old one, kill again.+- The dev pin does not stop an explicit `bridge_install` (ab 2.1.66, adom-bridge#159). On a shared+ box tell the other threads, or expect your staged build to vanish.+- After a build, push the non-runtime source too (tests/, demo/, tools/, RELEASE_NOTES.md): the+ release tool pushes only what the zip ships.
skills/kicad-bridge-test/run_verb_tests.py+4@@ -166,6 +166,10 @@ def matrix(w: dict) -> dict: "close_3d_viewer": dict(phase=6, args={}), "close": dict(phase=6, args={"force": True}, timeout=120, note="final teardown — leaves the box with no KiCad windows"),+ # Routing verbs need KiCad IPC and a dedicated unrouted board: covered by tests/ and demo/routing/run_demo.py.+ **{verb: dict(skip="Covered by tests/test_routing_ipc.py and demo/routing/run_demo.py; requires a dedicated unrouted IPC board")+ for verb in ("routing_state", "route_net", "remove_route", "routing_validate",+ "board_pads", "add_track", "add_via", "route")}, # ---- explicit skips (reason required — counted as covered) "enable_software_opengl": dict(skip="mutates the user's KiCad bin/ (mesa deploy) — only for GPU-less " "VMs; run manually on ADOMBASELINE when testing that path"),